Whole-body non-prehensile manipulation allows quadrupedal robots to reposition large objects through contact, but reliable performance remains difficult because pushing depends on object geometry, friction, mass, and intermittent contact dynamics. This paper presents a hierarchical rein- forcement learning pipeline in IsaacLab for goal-conditioned whole-body quadrupedal pushing across diverse cuboid and cylindrical objects. A high-level policy outputs planar velocity commands, while a frozen low-level locomotion controller pro- vides stable execution. During training, the policy is conditioned on privileged object-context features available in simulation, allowing us to study what a strong simulation pipeline can achieve under substantial geometry and physics variation. We evaluate the learned policy under in-distribution conditions, out-of-distribution geometry, out-of-distribution physics, and on unseen geometries not encountered during training. The results show that the privileged pipeline achieves robust whole-body pushing across object families and provides a strong benchmark for future work on deployable adaptation.
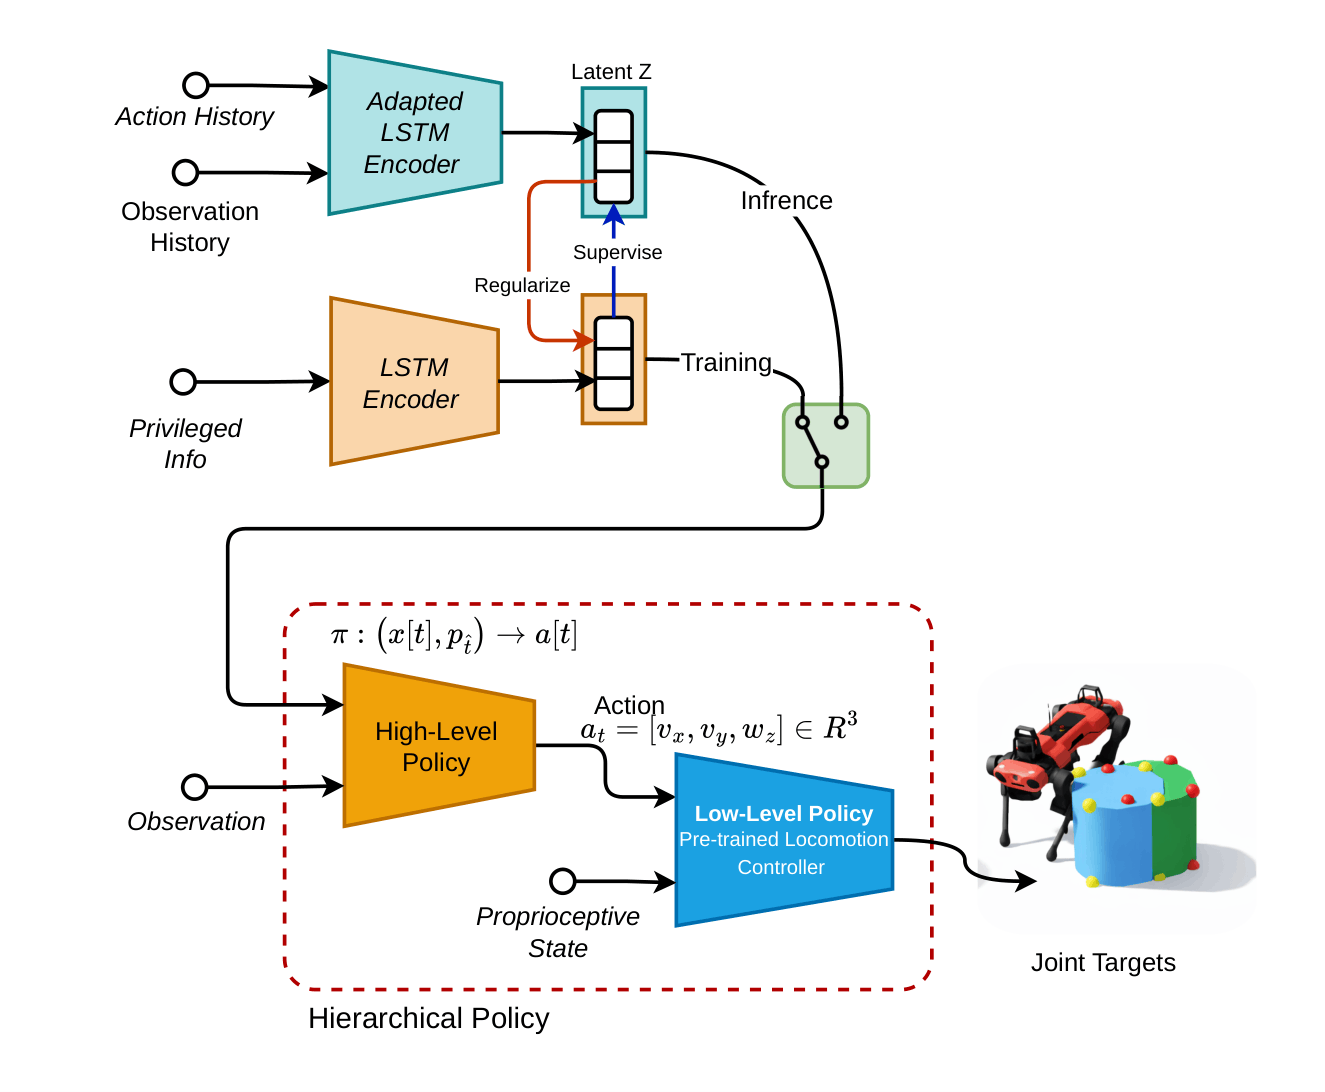
Our hierarchical policy consists of a high-level policy that generates actions for a pre-trained low-level locomotion controller. The system adapts to different geometries and physical parameters to achieve robust pushing.

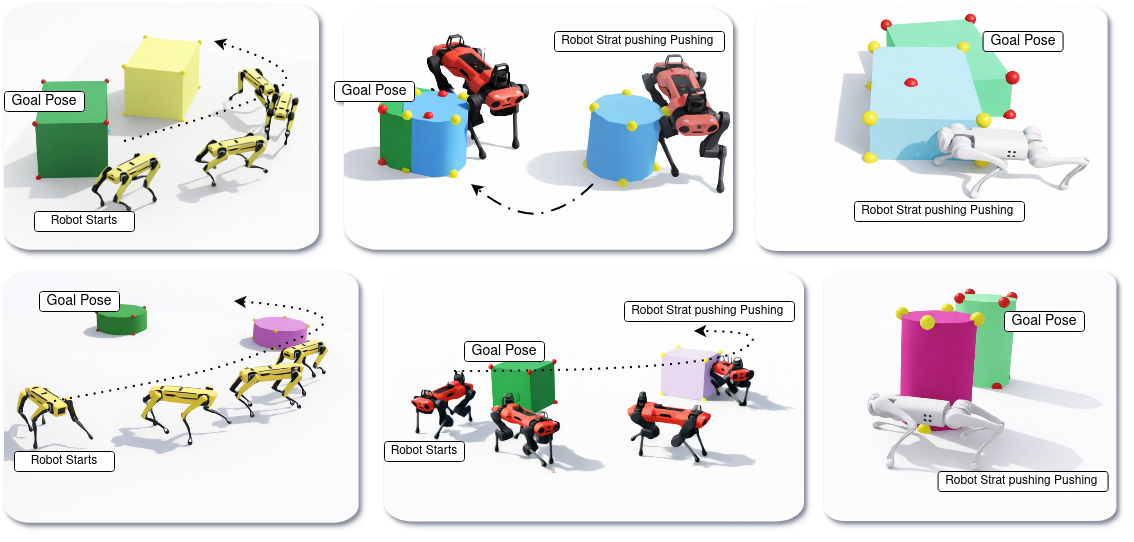
Our policy can push a variety of objects with different geometries and physical properties to target locations successfully, as demonstrated in these simulation rollouts.
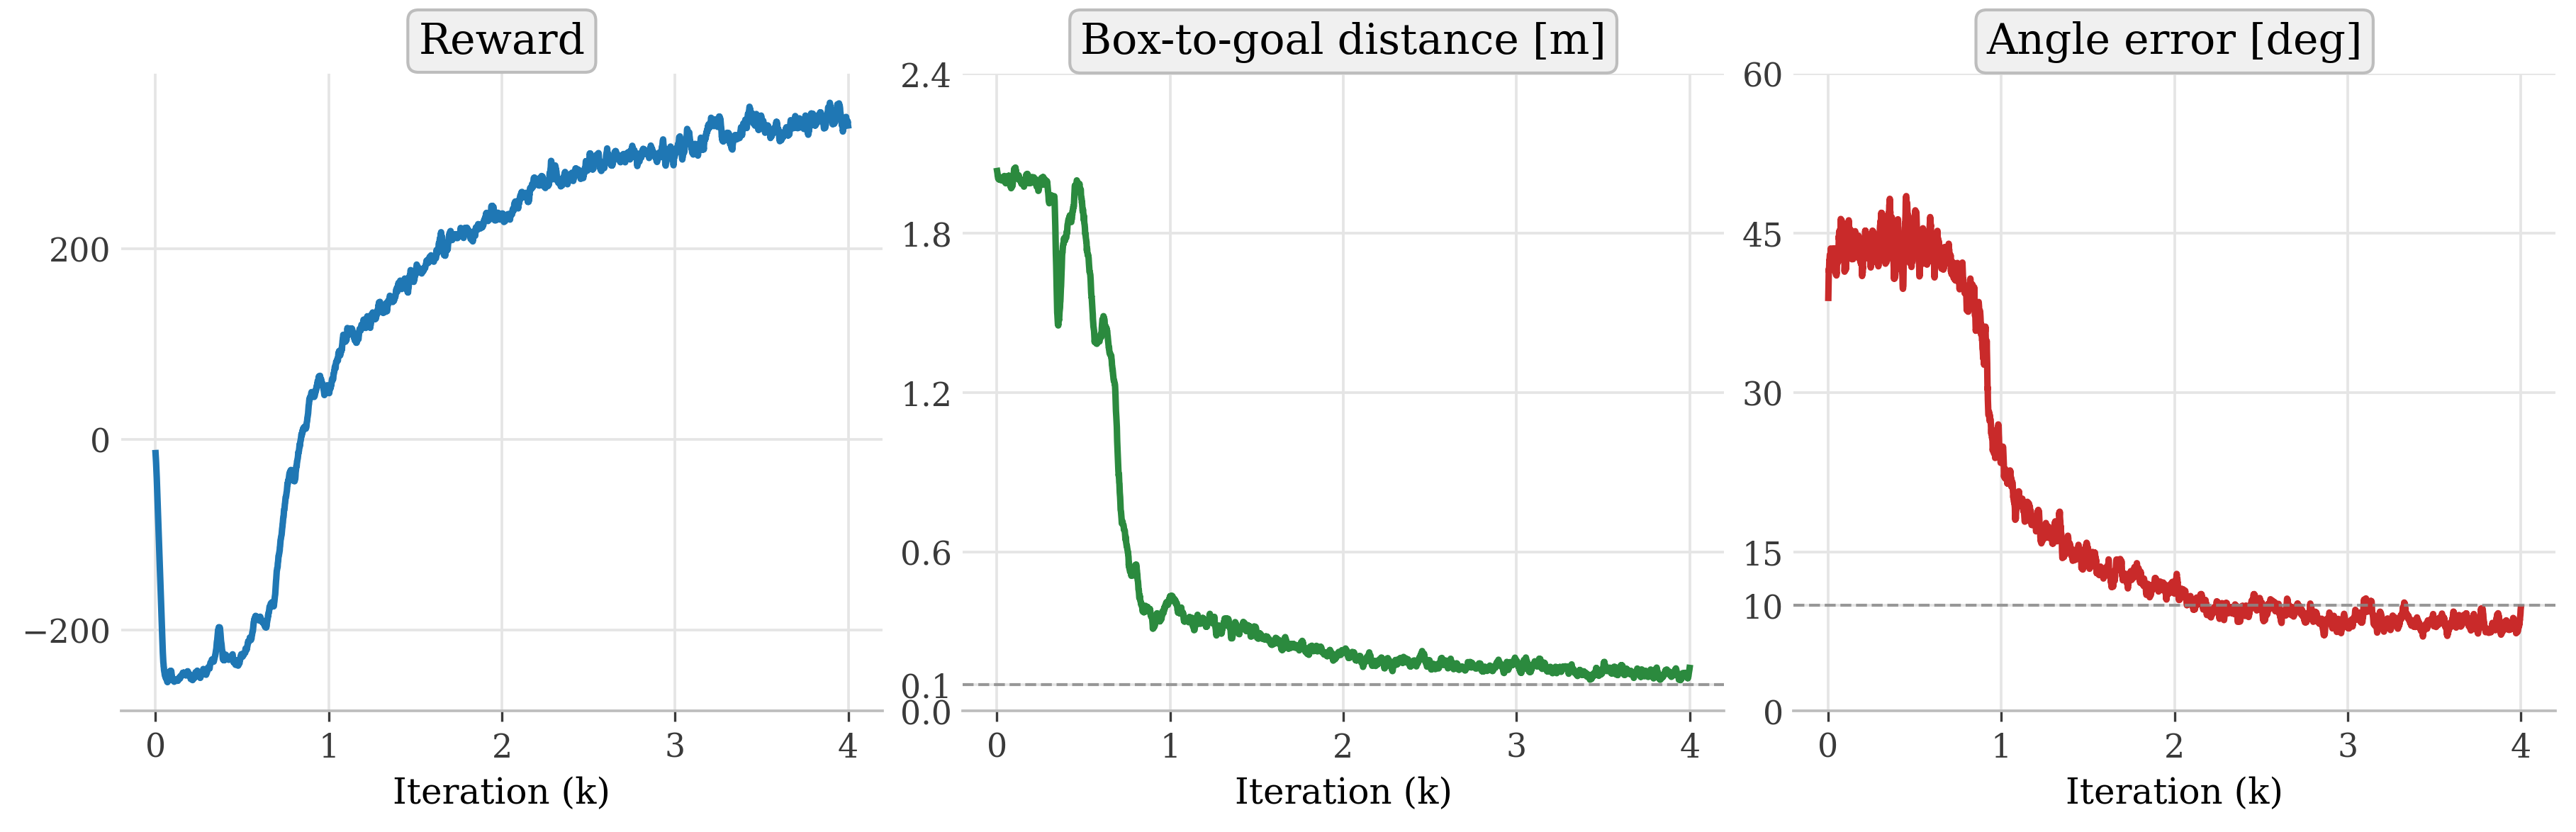
The plot above illustrates the overall performance and accumulated rewards over time across varying object types and physical settings.
@article{anonymous2026quadruped,
  author    = {Anonymous Submission},
  title     = {Learning Whole-Body Quadrupedal Pushing Across Geometry and Physics Variation},
  journal   = {ICRA},
  year      = {2026},
}